Office Cleaner on a Unitree G1: one night shift, checked rule by rule
The robot gets the building's floor plan and nothing else. Each of the 16 rules below says what is measured, the number, the limit, where to see it in the video or on a map, and what the check does not cover.
First build · v0.1Unitree G1 · Unitree walking policyMuJoCo physicsTested October 2026Real test data, not sample numbers
15/16rules passed
146 m²mopped in 52 min
72 %of real free floor
4 cmmean position error
0contacts · wet steps · falls
Summary
All numbers come from the simulator's ground truth: true positions, true contacts, the floor that was really mopped. Pick a rule for the details.
Rule
What is checked
Result
Limit
Status
OC-01
Reads the floor plan →Rooms, doors and entrance found on two plans (image + PDF), names read, areas vs. drawing
Mops the floor →Share of the real free floor mopped (ground truth), cleaned rooms
72 % · 146 of 202 m²
≥ 90 %
NOT YET
Rule by rule
The buttons with a time jump the video to that moment.
OC-01
Reads the floor plan
PASS
Measured
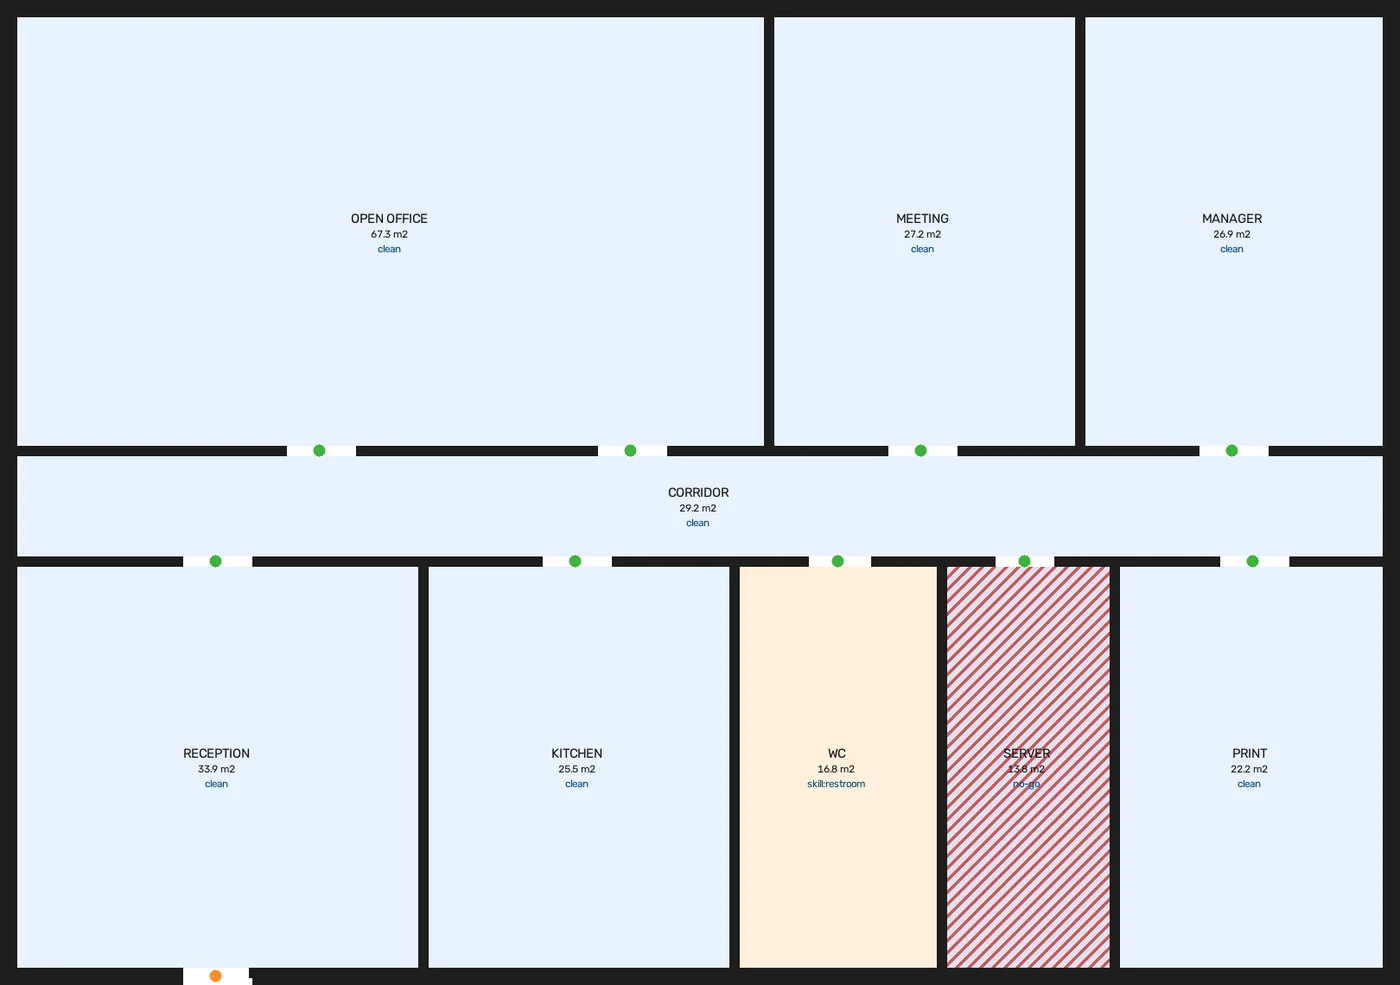
The plan reader gets the architect's drawing and must find every room, door and the entrance, read the room names and measure each room. Its output is compared with the geometry the drawing was made from. Plan A is read twice, as an image and as a PDF (scale read from the title block); plan B once.
What the robot read from plan A: rooms coloured by their rule (blue clean, beige needs the Restroom skill, hatched no-go), doors in green, the entrance in orange.Room areas, plan A: read vs. drawing
Room
Read m²
Drawing m²
Error
OPEN OFFICE
67.30
67.22
0.13 %
MEETING
27.24
27.22
0.07 %
MANAGER
26.87
26.82
0.19 %
CORRIDOR
29.24
29.23
0.03 %
RECEPTION
33.87
33.81
0.16 %
KITCHEN
25.49
25.47
0.08 %
WC
16.76
16.75
0.08 %
SERVER
13.85
13.84
0.07 %
PRINT
22.23
22.18
0.21 %
What this check does not cover. Both plans are clean, CAD-style drawings with straight walls. Scanned paper plans, hand sketches and curved walls are not tested yet. For an image without a scale the customer marks one wall of known length.
OC-02
Knows where it is
PASS
Measured
Every 0.25 s the robot's own estimate of where it stands is compared with its true position in the simulator, for the whole 52-minute shift (12,560 samples). The robot only has its LiDAR, its leg odometry and the plan.
Result
mean 4 cm, max 11 cm
Limit
mean ≤ 10 cm, max ≤ 25 cm
Position error over the shift (worst in each 10 s)
What this check does not cover. The simulated LiDAR has 1.2 cm noise and sees walls and furniture cleanly. Glass walls, mirrors and long empty corridors in real buildings are harder.
OC-03
Never enters a no-go room
PASS
Measured
At every sample the robot's true position is checked against the floor of the server room (no-go). Separately: did it enter any room that is not in the package (the WC needs the Restroom skill)?
Result
0 / 0
Limit
0 / 0
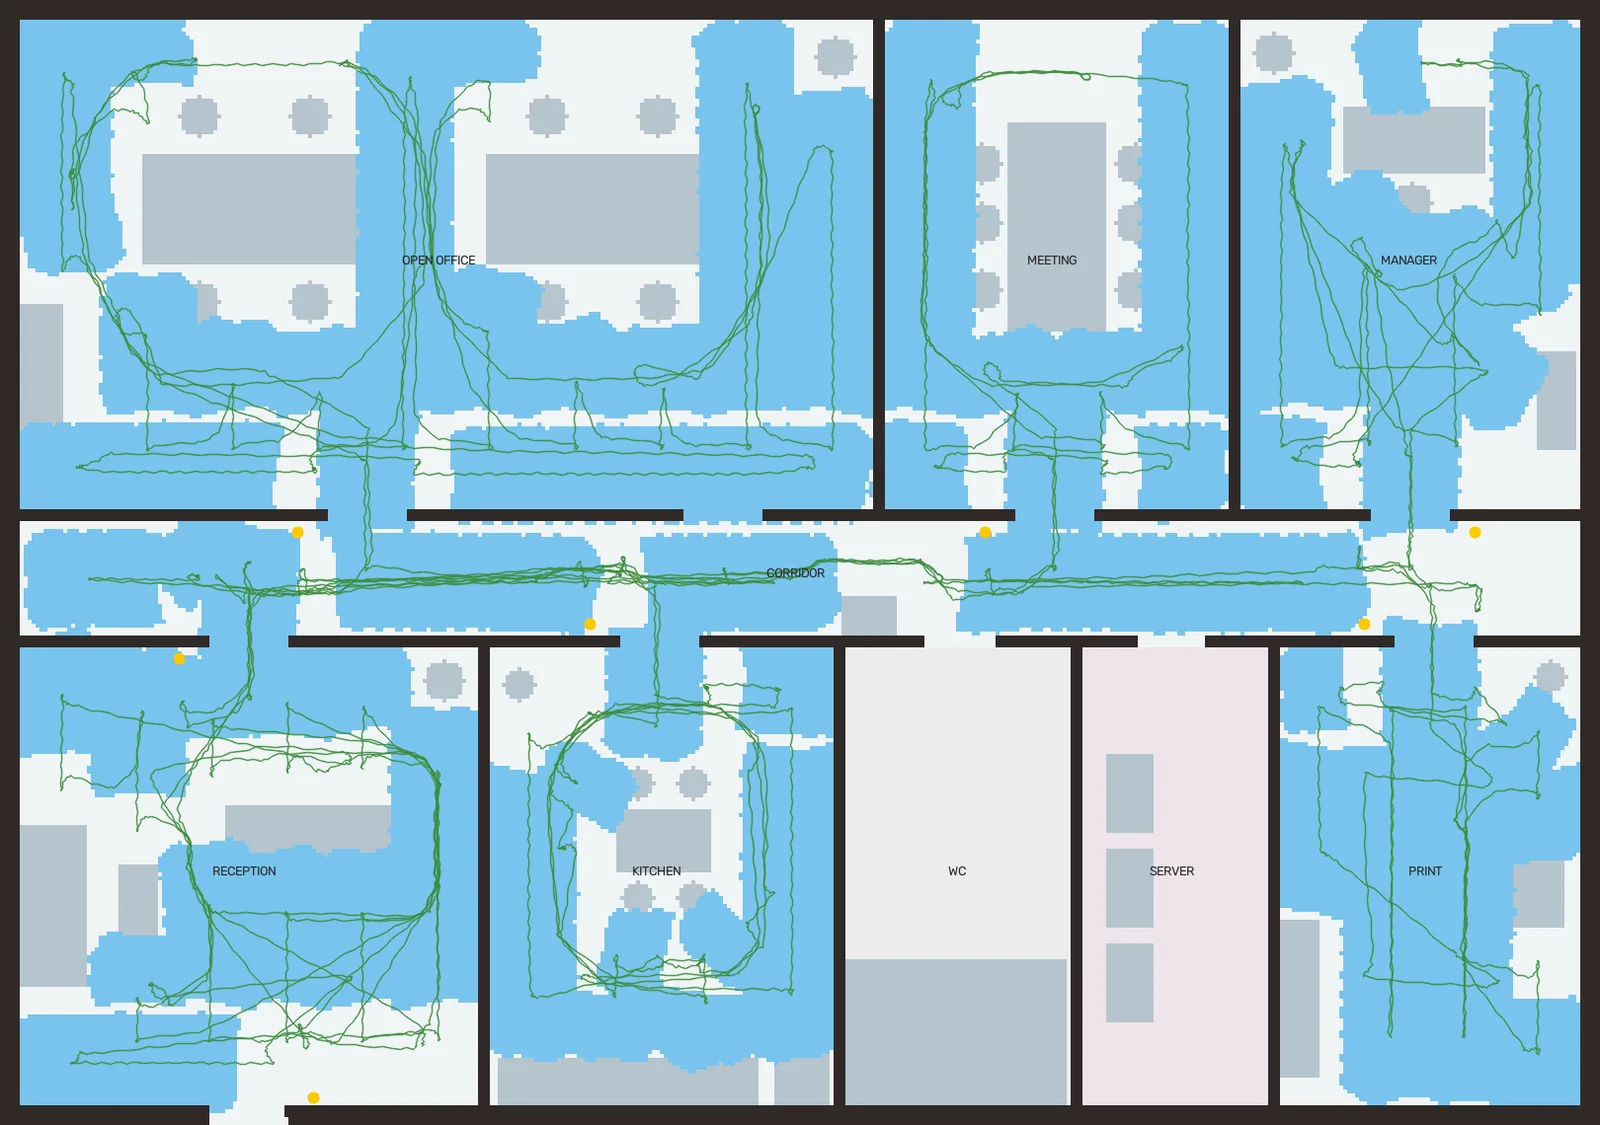
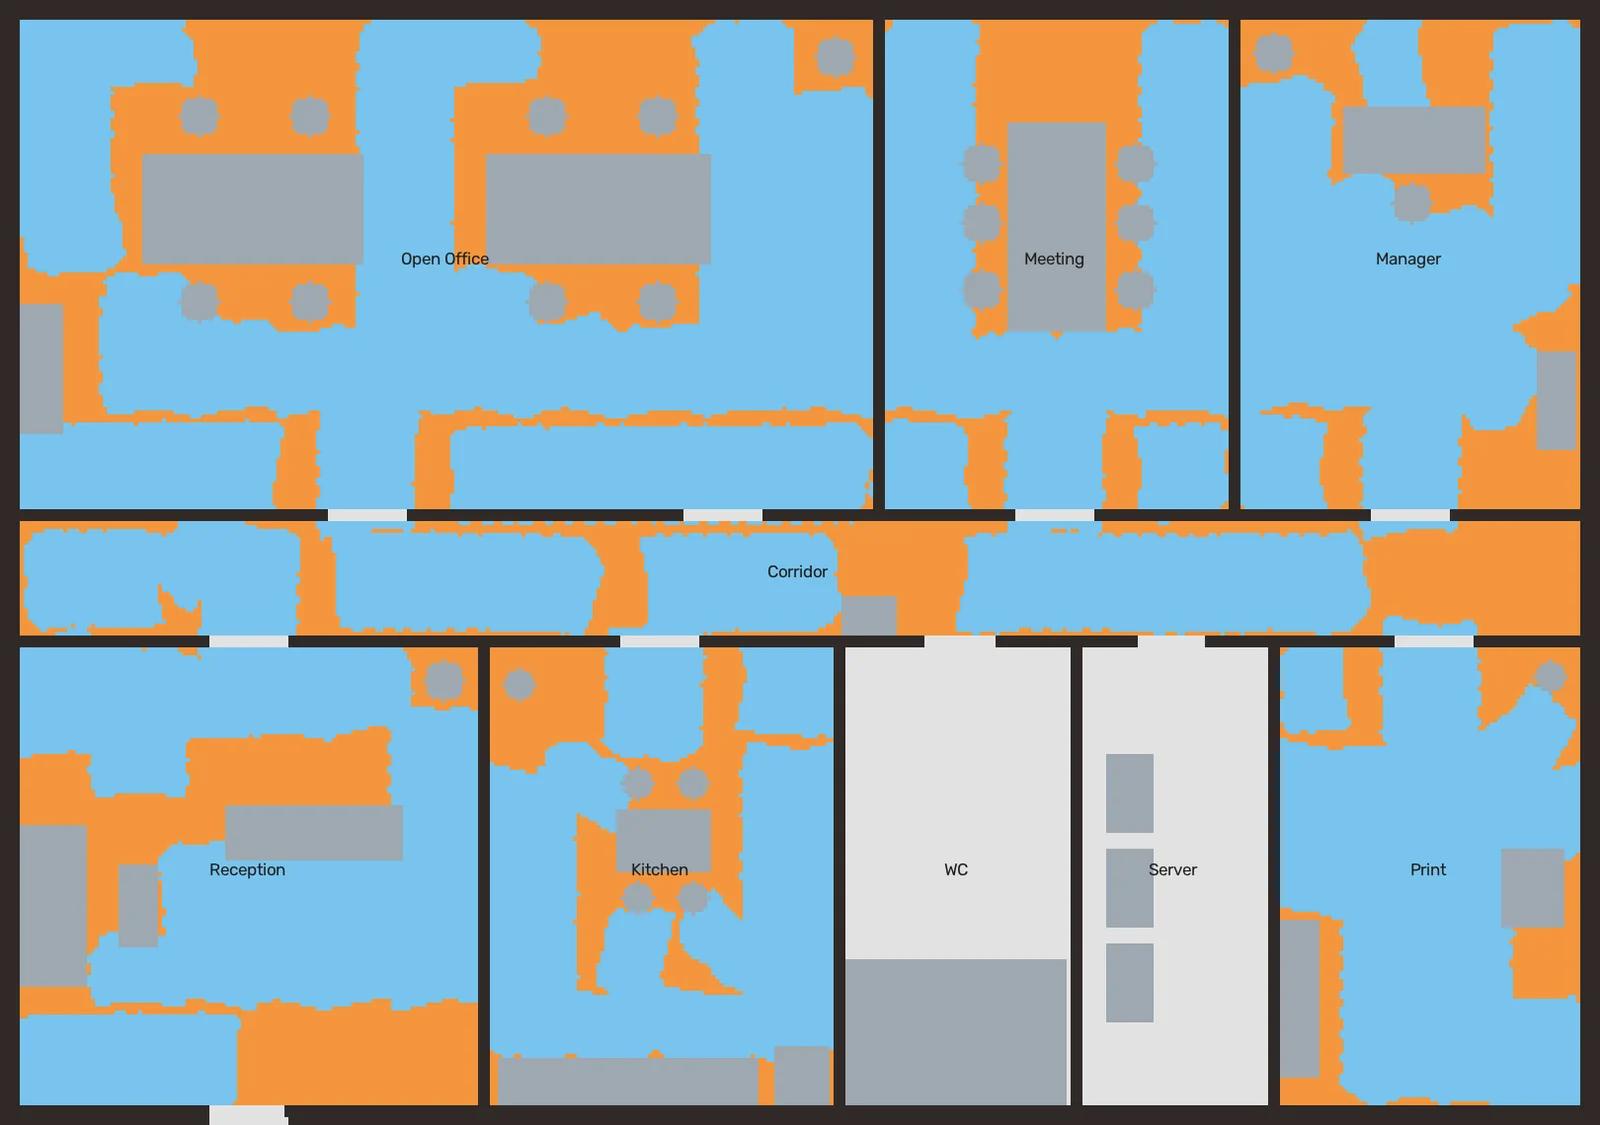
The robot's true path (green) over the whole shift. Server and WC stay untouched; the closest it came to the server room was 0.65 m, walking along the corridor.
What this check does not cover. Covers whole rooms the plan reader marked. A no-go area inside a room (a cable zone, a cash desk) would be drawn by the customer in the app; that is not tested yet.
OC-04
Stops for people
PASS
Measured
Any moment the robot walks faster than 0.1 m/s (true speed, averaged over 0.5 s) while a person is within 1 m of it. Two colleagues walk through during the shift; one walks straight towards the robot in the open office, one comes up to it in the corridor and stops to look.
Result
0 times · closest person 0.62 m
Limit
0
Distance to the colleague (m)Robot speed (m/s)
What this check does not cover. People walk set paths, and the camera's person detector is emulated (it sees 95 % of people in view). Crowds, children, people sitting on the floor and pets are not tested. The closest approach (0.62 m) happened while the robot stood still and the colleague walked past.
OC-05
Touches nothing
PASS
Measured
The physics engine lists every contact between a robot body part and anything that is not the floor: walls, furniture, doors, people, wet-floor signs, the dock. Checked every 0.02 s, the whole shift.
Result
0
Limit
0
0 contacts. The nearest wall or piece of furniture the LiDAR saw was 0.28 m from the robot's centre.
What this check does not cover. Furniture is solid boxes and cylinders: thin chair legs, cables on the floor and glass are not in the simulation. The mop head is a simplified tool and is not part of the contact check.
OC-06
Never steps on wet floor
PASS
Measured
Every 0.02 s, each foot that touches the floor is checked against the floor's mopping history. A foot on floor mopped between 1.5 s and 2.5 minutes earlier is a wet step.
Result
0
Limit
0
0 wet steps. To stay off wet floor it waited for floor to dry 6 times, 15 minutes in total (longest 180 s), and picked strokes it could reach on dry floor first.
What this check does not cover. Drying time is a fixed 2.5 minutes. Real drying depends on the floor, the mop and the air; on the real robot it should come from the site settings.
OC-07
Wet-floor sign first
PASS
Measured
For each room: when the wet-floor sign was put at the door, and when the mop first touched that room's floor.
Result
7/7 rooms
Limit
every room
Room
Sign placed
First stroke
Sign first by
Manager
1:12
2:19
67 s
Print
8:33
9:28
54 s
Meeting
12:37
14:05
89 s
Open Office
17:02
18:59
117 s
Kitchen
29:15
30:28
72 s
Corridor
39:35
40:30
55 s
Reception
46:28
47:26
58 s
What this check does not cover. Placing the sign is simulated as a pause at the door; the hand skill of carrying and opening a real sign is not.
OC-08
Finds what is not on the plan
PASS
Measured
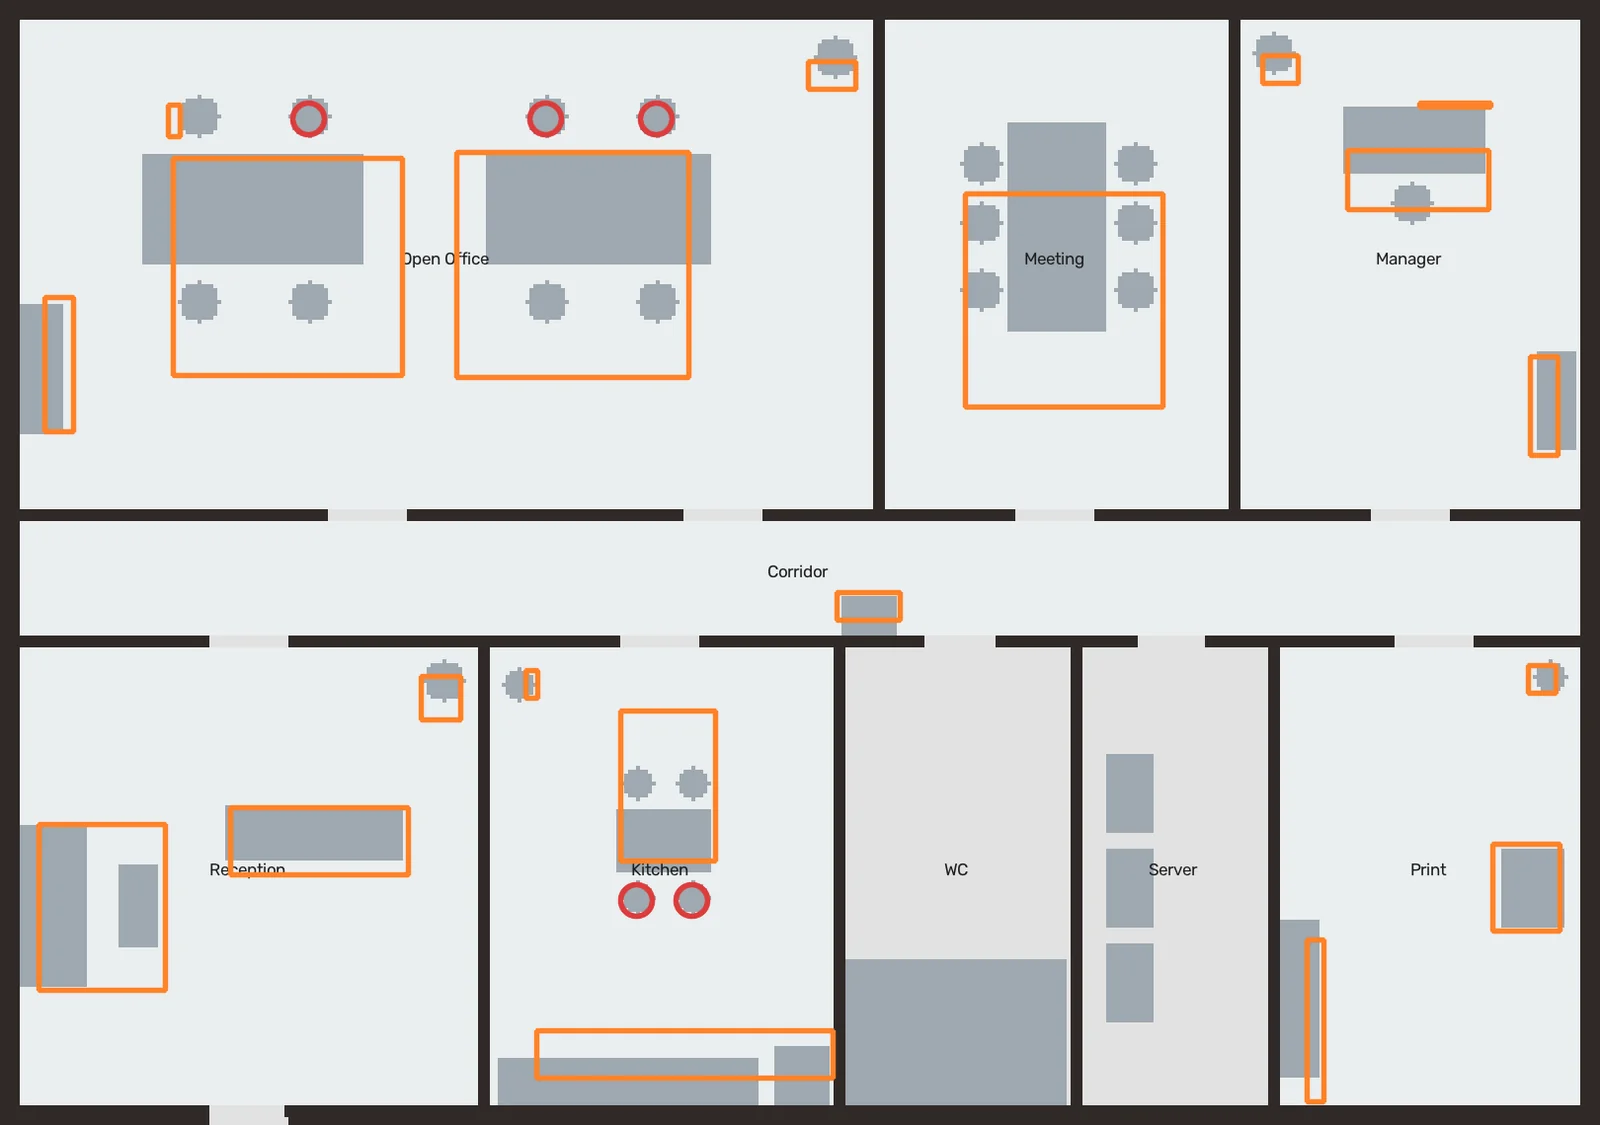
The plan shows walls and doors only. Everything the robot finds in the rooms it cleans goes into the morning report as a box. A real item counts as found if a reported box overlaps it (15 cm tolerance). The rule counts furniture and boxes of 60 cm and more; chairs and bins are listed but not counted, because they move every day.
Result
16/16 · chairs and bins 18/23
Limit
≥ 90 %
Real furniture in grey, what the robot reported in orange (20 boxes). Red rings: the 5 chairs it did not report.
What this check does not cover. The boxes are coarse: a desk and its chairs often come back as one box. Small things (a bag, a cable) are below what this version reports.
OC-09
Opens a closed door
PASS
Measured
The manager's door is closed when the shift starts. Pass if the robot asks the building's access system through Botisoft Cloud, the door opens and the room gets cleaned.
Result
opened in 3.5 s
Limit
room cleaned
1:12Reaches door D4: closed. Asks the building system through Botisoft Cloud.
1:16Door open, 3.5 s later. Goes in; the Manager room is cleaned.
What this check does not cover. The building's access system is simulated. Real access-control systems are not connected yet; each one needs its own integration.
OC-10
Keeps working offline
PASS
Measured
The network is cut for 90 s while the robot works in the meeting room. Every event the robot sends to the cloud is counted at both ends. Pass if nothing is lost and the order is kept.
Result
3 events buffered and synced · 63/63 delivered
Limit
nothing lost
63 events sent, 63 received, in order. 3 were kept on the robot during the outage and sent when the network came back. Mopping did not stop.
What this check does not cover. During an outage the operator cannot reach the robot; a Pause pressed then arrives when the network is back. Safety and navigation run on the robot and never wait for the network.
OC-11
Obeys the operator
PASS
Measured
The operator presses Pause in Botisoft Cloud at 29:30 while the robot walks. Measured: time from the command until the robot's true speed is under 0.1 m/s.
Result
0.7 s
Limit
≤ 1.0 s
Robot speed around the Pause (m/s)
What this check does not cover. Cloud delay is simulated as near zero; on a real network add the round-trip time. The robot's own emergency stop is the robot maker's and is not part of this test.
OC-12
Goes home on low battery
PASS
Measured
A separate run that starts with 23.5 % battery. Pass if the robot decides to go home in time and docks with at least 15 % left.
Result
docked with 23 %
Limit
docks with ≥ 15 %
0:21Battery 23.2 %: below its reserve for the way home. Stops work and heads for the dock.
0:51Docked with 22.8 %.
What this check does not cover. The robot started next to its reserve, so this checks the decision and the way home, not a whole shift of battery planning. The battery is a simple power model. This run has no video.
OC-13
Copes when the door and network both fail
PASS
Measured
A separate run: the manager's door is closed and the network goes down for 200 s just as the robot gets there, so it cannot ask for the door. Pass if it does not stall or force the door, and the room is cleaned once that is possible.
Result
kept working, retried the door; network back → door opened, room cleaned
Limit
no stall
1:12At door D4: closed
2:12Still closed, no network: tries again
2:13At door D4: closed
3:13Still closed, no network: tries again
3:14At door D4: closed
3:41Network back: asks the building system
3:45Door open; Manager room cleaned
What this check does not cover. While it waited, the robot stayed at the door and asked again every minute instead of cleaning another room first. Next version: do the other rooms and come back.
OC-14
Works in a building it has never seen
PASS
Measured
The same profession, with no changes, on a second building it has never seen: an L-shaped open space and nine more rooms. Same checks as the main shift.
Result
8 rooms done · 0 contacts · 0 wet steps
Limit
all rooms, 0 / 0
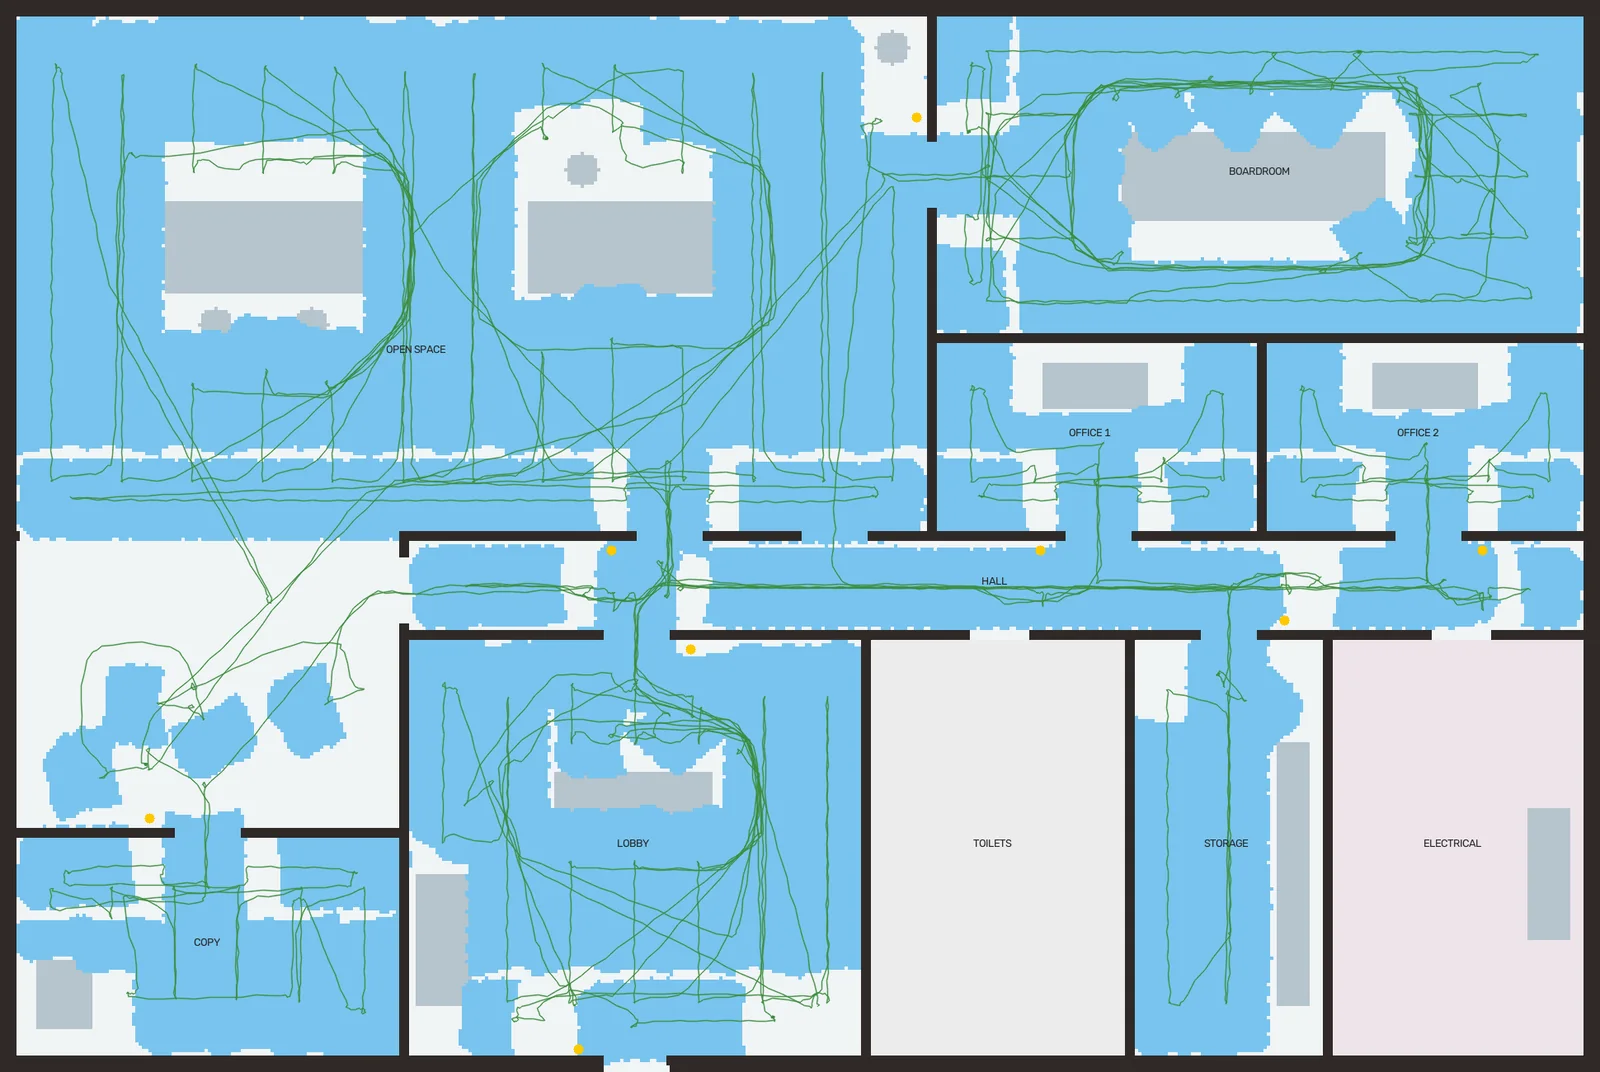
Plan B after the shift: 8 rooms mopped in 65 min, 79 % of the free floor, 0 contacts, wet steps or falls. The electrical room was never entered; the toilets were left for the Restroom skill.
What this check does not cover. This run has no people, door or network events; it checks plan reading, finding the way and mopping in a new layout.
OC-15
Stays upright
PASS
Measured
A fall is the pelvis below 0.5 m or the body tilted more than about 53°. Checked every 0.02 s in all runs.
Result
0
Limit
0
0 falls. The pelvis never went below 0.76 m (standing height 0.78 m).
What this check does not cover. Flat floor only. Door thresholds, ramps, stairs and a slippery wet floor are not in the physics yet.
OC-16
Mops the floor
NOT YET
Measured
The simulator records every 5 × 5 cm piece of floor the mop actually touched. Share = mopped floor ÷ free floor (room floor minus the real furniture) in the seven rooms cleaned.
Result
72 % · 146 of 202 m²
Limit
≥ 90 %
Mopped floor in blue, missed free floor in orange, furniture in grey. Grey rooms were not in the package.
Mopped share by distance from walls and furniture
Within 30 cm of a wall or furniture56 % · 35 of 64 m²
30 to 60 cm away75 % · 50 of 68 m²
Open floor, over 60 cm away85 % · 60 of 71 m²
Room
Free m²
Mopped m²
Share
Minutes
Manager
24.1
18.6
77 %
8.4
Print
20.1
16.5
82 %
3.8
Meeting
22.4
16.8
75 %
4.0
Open Office
56.3
40.4
72 %
12.8
Kitchen
21.2
15.4
73 %
10.0
Corridor
28.3
18.6
66 %
7.0
Reception
29.6
19.9
67 %
6.3
Why not yet. The open floor is 85 % mopped; the misses sit next to walls and furniture.
The robot keeps its body about 40 cm from walls and furniture when it walks and turns, and the mop reaches only partly into that gap.
Floor between chairs and desks is too narrow for its body, and it does not move chairs.
7 strokes were cut short because something was behind the robot.
Next: an edge pass with the mop held to the side, moving chairs aside, and a trained mopping hand skill on the real robot.
What this check does not cover. The mop is a simplified tool that follows the robot; how clean the floor really gets (pressure, water, dirt) is not simulated.
How it was tested
Unitree's own G1 model and walking controller, in MuJoCo physics.
The simulator adds what the plan does not show: real furniture, two colleagues walking through, a locked door, a 90 s network outage and an operator pressing Pause.
Extra runs: a shift that starts on a low battery, a locked door while the network is down, and a second building.
The robot only gets its sensors and the plan. The checks use the simulator's ground truth.
What is simulated, and what is next
This is a simulation. The real-robot adapter is written for Unitree's SDK but has not run on a G1 yet.
Hand work is simplified: the mop follows the robot and placing the sign is a pause. A real mopping skill needs training data.
Furniture is solid shapes; people walk set paths; the camera's person detector is emulated.
Next: the same 16 rules on a real robot, with a partner.
Run the same tests on a real robot
We are looking for robot makers and partners to take the Office Cleaner from simulation to a real G1 and a real building.